183
社区成员
 发帖
 与我相关
 我的任务

 分享
| The Link Your Class | https://bbs.csdn.net/forums/MUEE308FZ |
|---|---|
| The Link of Requirement of This Assignment | https://bbs.csdn.net/topics/603251839 |
| The Name of Team | East Wind |
| The Goal of This Assignment | Alpha Sprint |
| Leader's MU STU ID and Name | 19104375 & 831902106 Xiaolong Han |
| Teammate 1's MU STU ID and Name | 19104600 & 831902123 Yongquan Wang |
| Teammate 2's MU STU ID and Name | 19104847 & 831902119 Jiatong Zhang |
| Teammate 3's MU STU ID and Name | 19104821 & 831902118 Shuoyuan Chen |
| Teammate 4's MU STU ID and Name | 19104952 & 831901329 Xiaotong Shao |
| Group number | 6 - A |
📜 Catalog
Everyone's progress today
| Completed task | Task Completion Duration | Problems with completing tasks | Handling |
|---|---|---|---|
| Write a daily Blog | 45mins |
| Completed task | Task Completion Duration | Problems with completing tasks | Handling |
|---|---|---|---|
| Learn about the database SpringBoot and try writing interfaces | All day long | There are so many problems that I don't know how to start. It takes a lot of time to configure the software environment, and it is difficult to implement several teaching videos in practical operation | |
| Learn how to use Java for applets call interfaces |
🏫This is the record of our study in Bilibili University
| Completed task | Task Completion Duration | Problems with completing tasks | Handling |
|---|---|---|---|
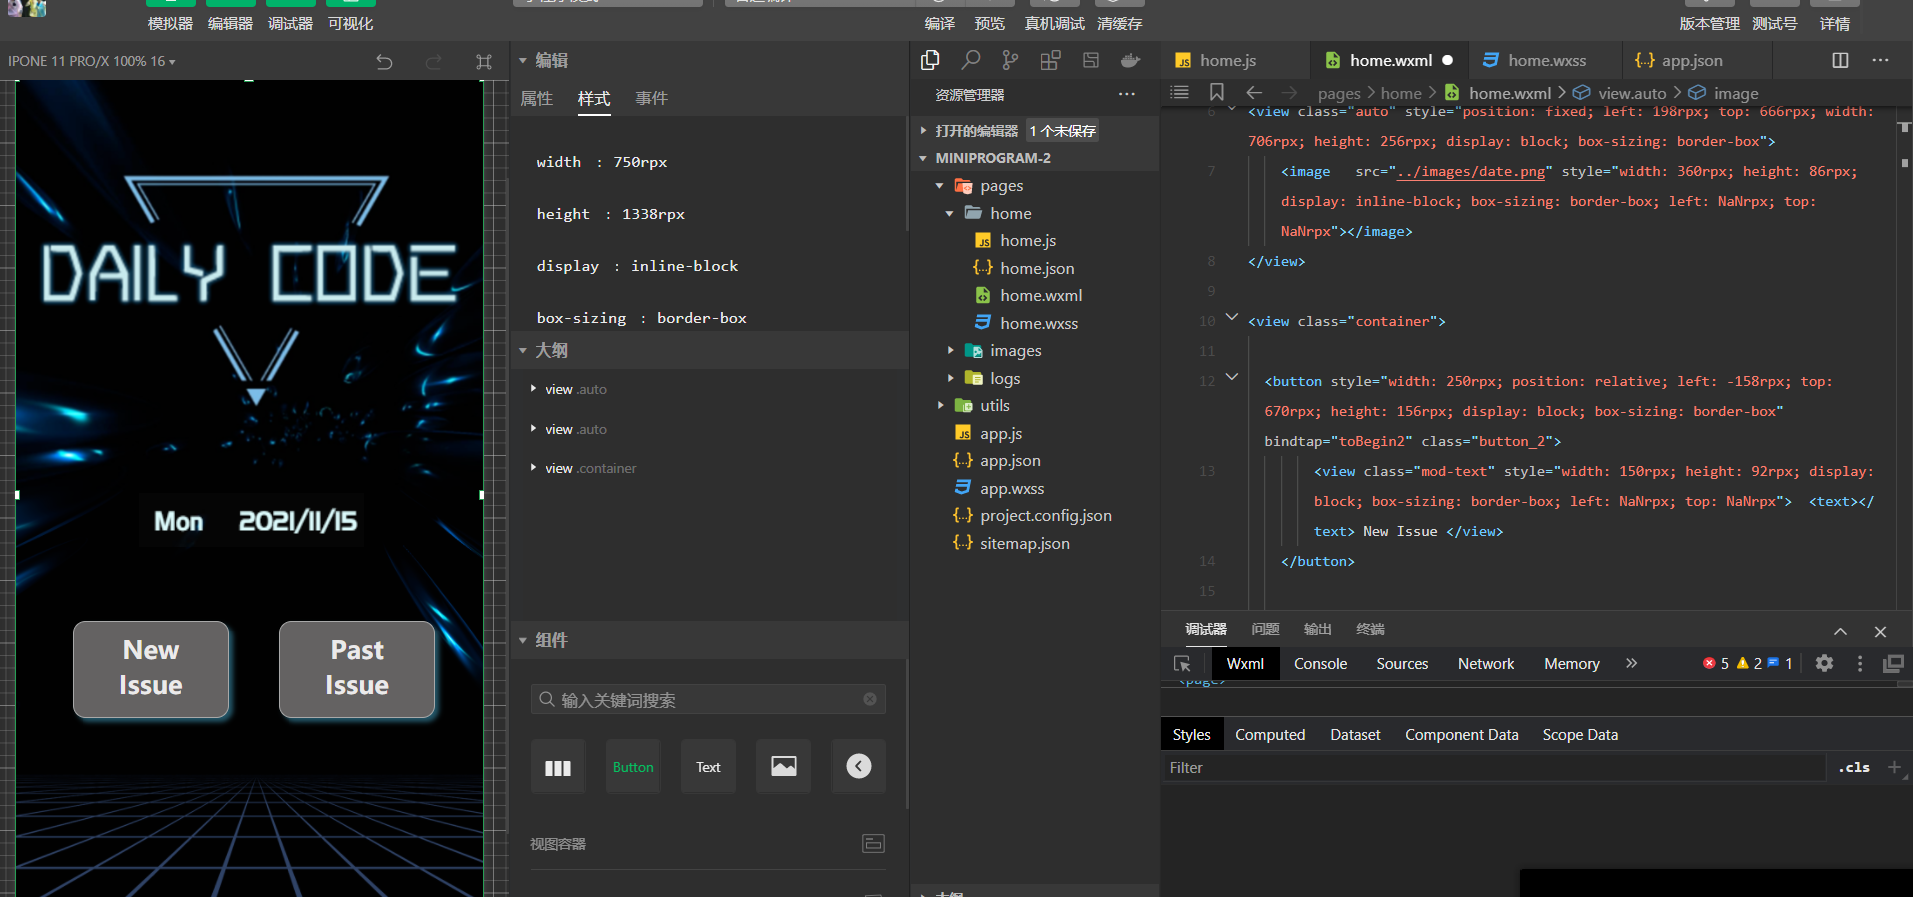
| Design homepage 2.0 | 60mins | Don't know how to code a lot of desired effects | Consult CSDN and many other articles, find the answer from it, and imitate the production principle according to the ink knife prototype. |
| Vlog record | 15mins |
Since we have not entered the testing stage, Mr.Shao has not been used at this stage, so we are more asking him to help other teammates
| Completed task | Task Completion Duration | Problems with completing tasks | Handling |
|---|---|---|---|
| Assist in Blog shooting | 15mins | ||
| Assist in Vlog shooting | 60mins |
| Member | Contribution Degree | Contribution Details |
|---|---|---|
| Xiaolong Han | 20% | Blog writing |
| Yongquan Wang | 20% | Learn about the database SpringBoot and try writing interfaces |
| Jiatong Zhang | 20% | Learn about the database SpringBoot and try writing interfaces |
| Shuoyuan Chen | 21% | Set up the Github Library and take vlogs |
| Xiaotong Shao | 19% | Assist team members in writing Blog and shooting Vlog |
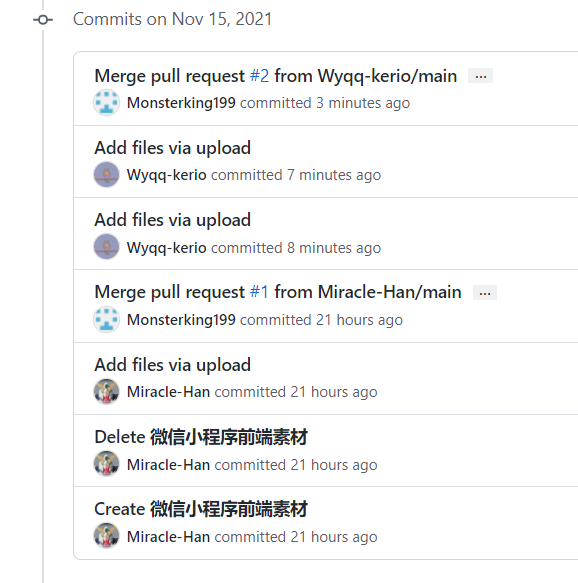
Here is our Github check-in record.